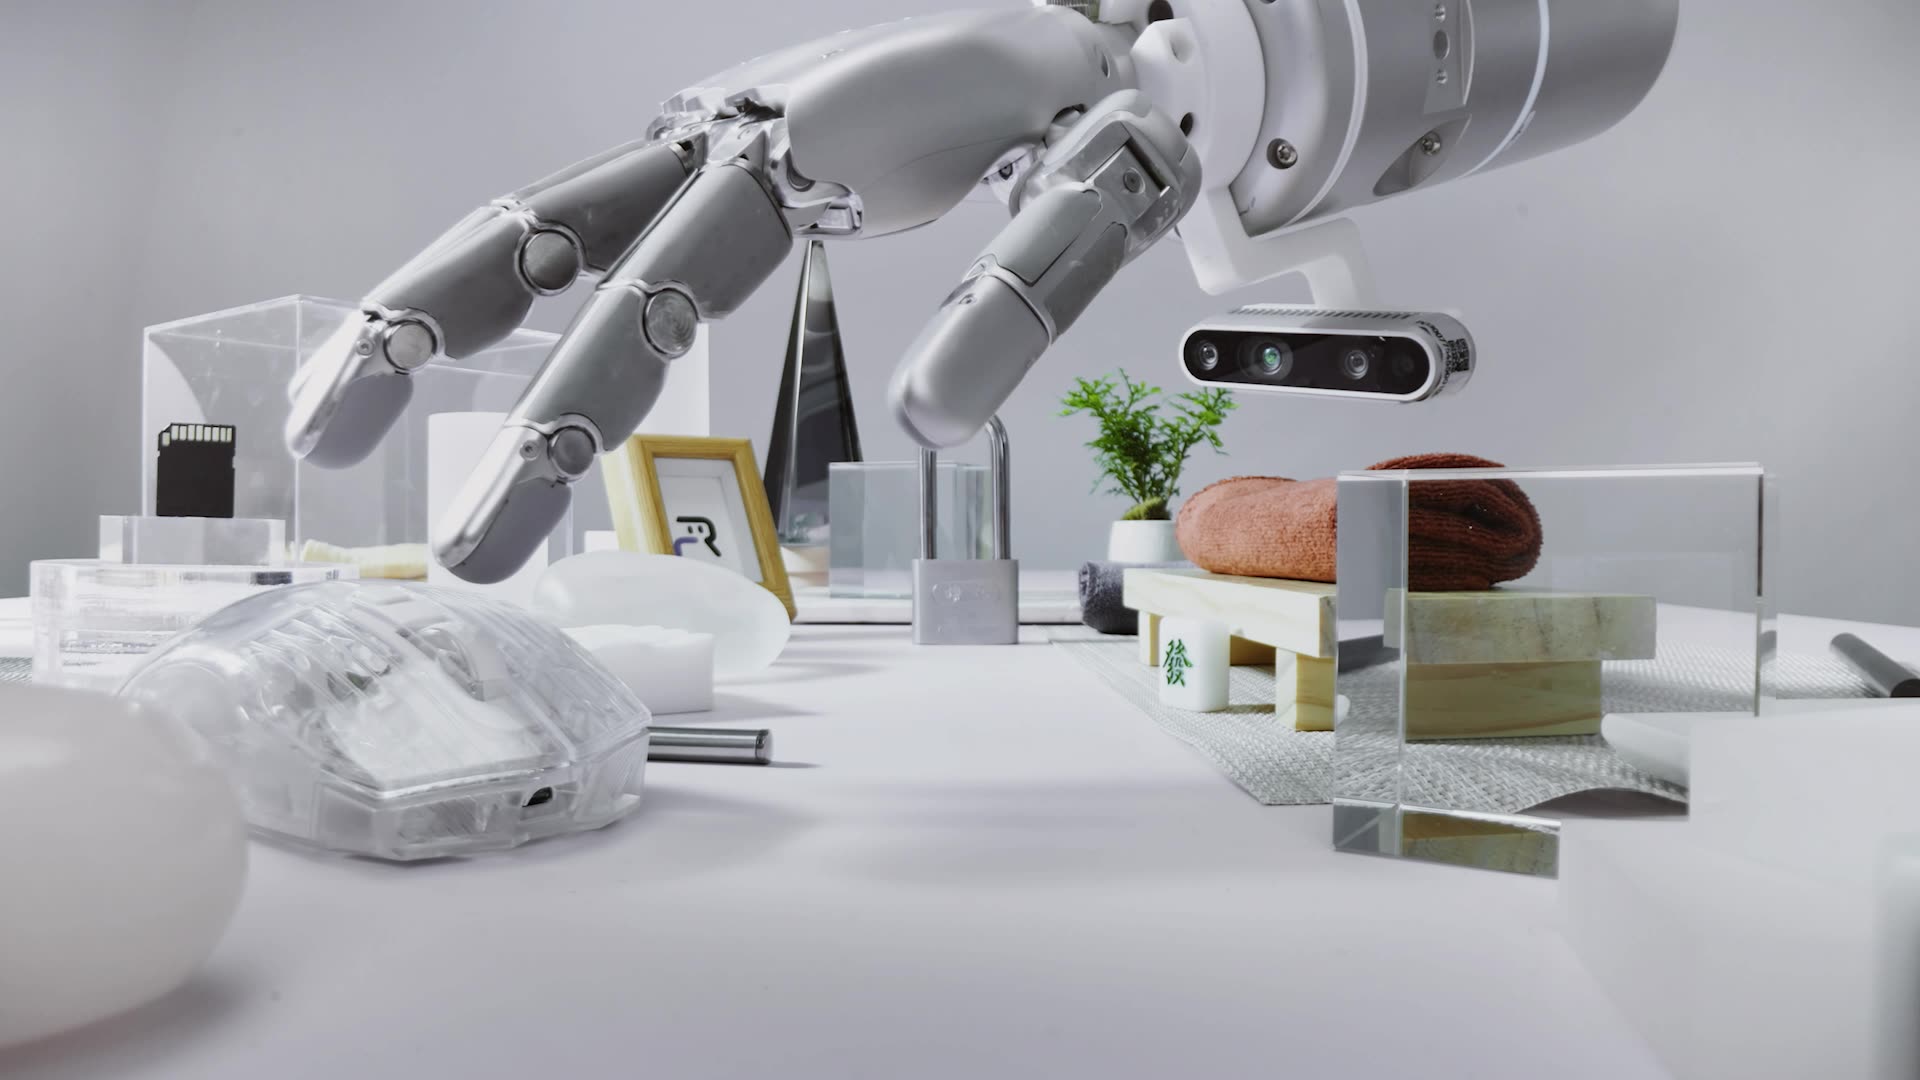
🤖 Ant Group's Robbyant releases tactile model LingBot-Touch
Ant Group's division has released the weights and inference code for the tactile model LingBot-Touch (Apache-2.0) along with a technical report arXiv:2611.12806. The JEPA model predicts latent representations of tactile signals, was trained on 4,983 hours of recordings from three types of sensors, and was validated on 26 real-world bimanual tasks.
🌍 Typically, a separate model is trained for each type of tactile sensor. LingBot-Touch maps piezoresistive, magnetic, and visuotactile signals into a common latent space—checkpoints can be used as a base. Transfer is currently confirmed only for Sharpa Wave and XHand.
👤 The Robbyant/lingbot-touch repository contains inference code, examples for Sharpa and XHand, and instructions (Python 3.12, PyTorch 2.11, CPU). Tiny and Small checkpoints are available on Hugging Face and ModelScope.
Source 1: https://github.com/Robbyant/lingbot-touch Source 2: https://technology.robbyant.com/lingbot-touch