🤖 HapticVLA: How to teach a robot to feel without touch sensors?
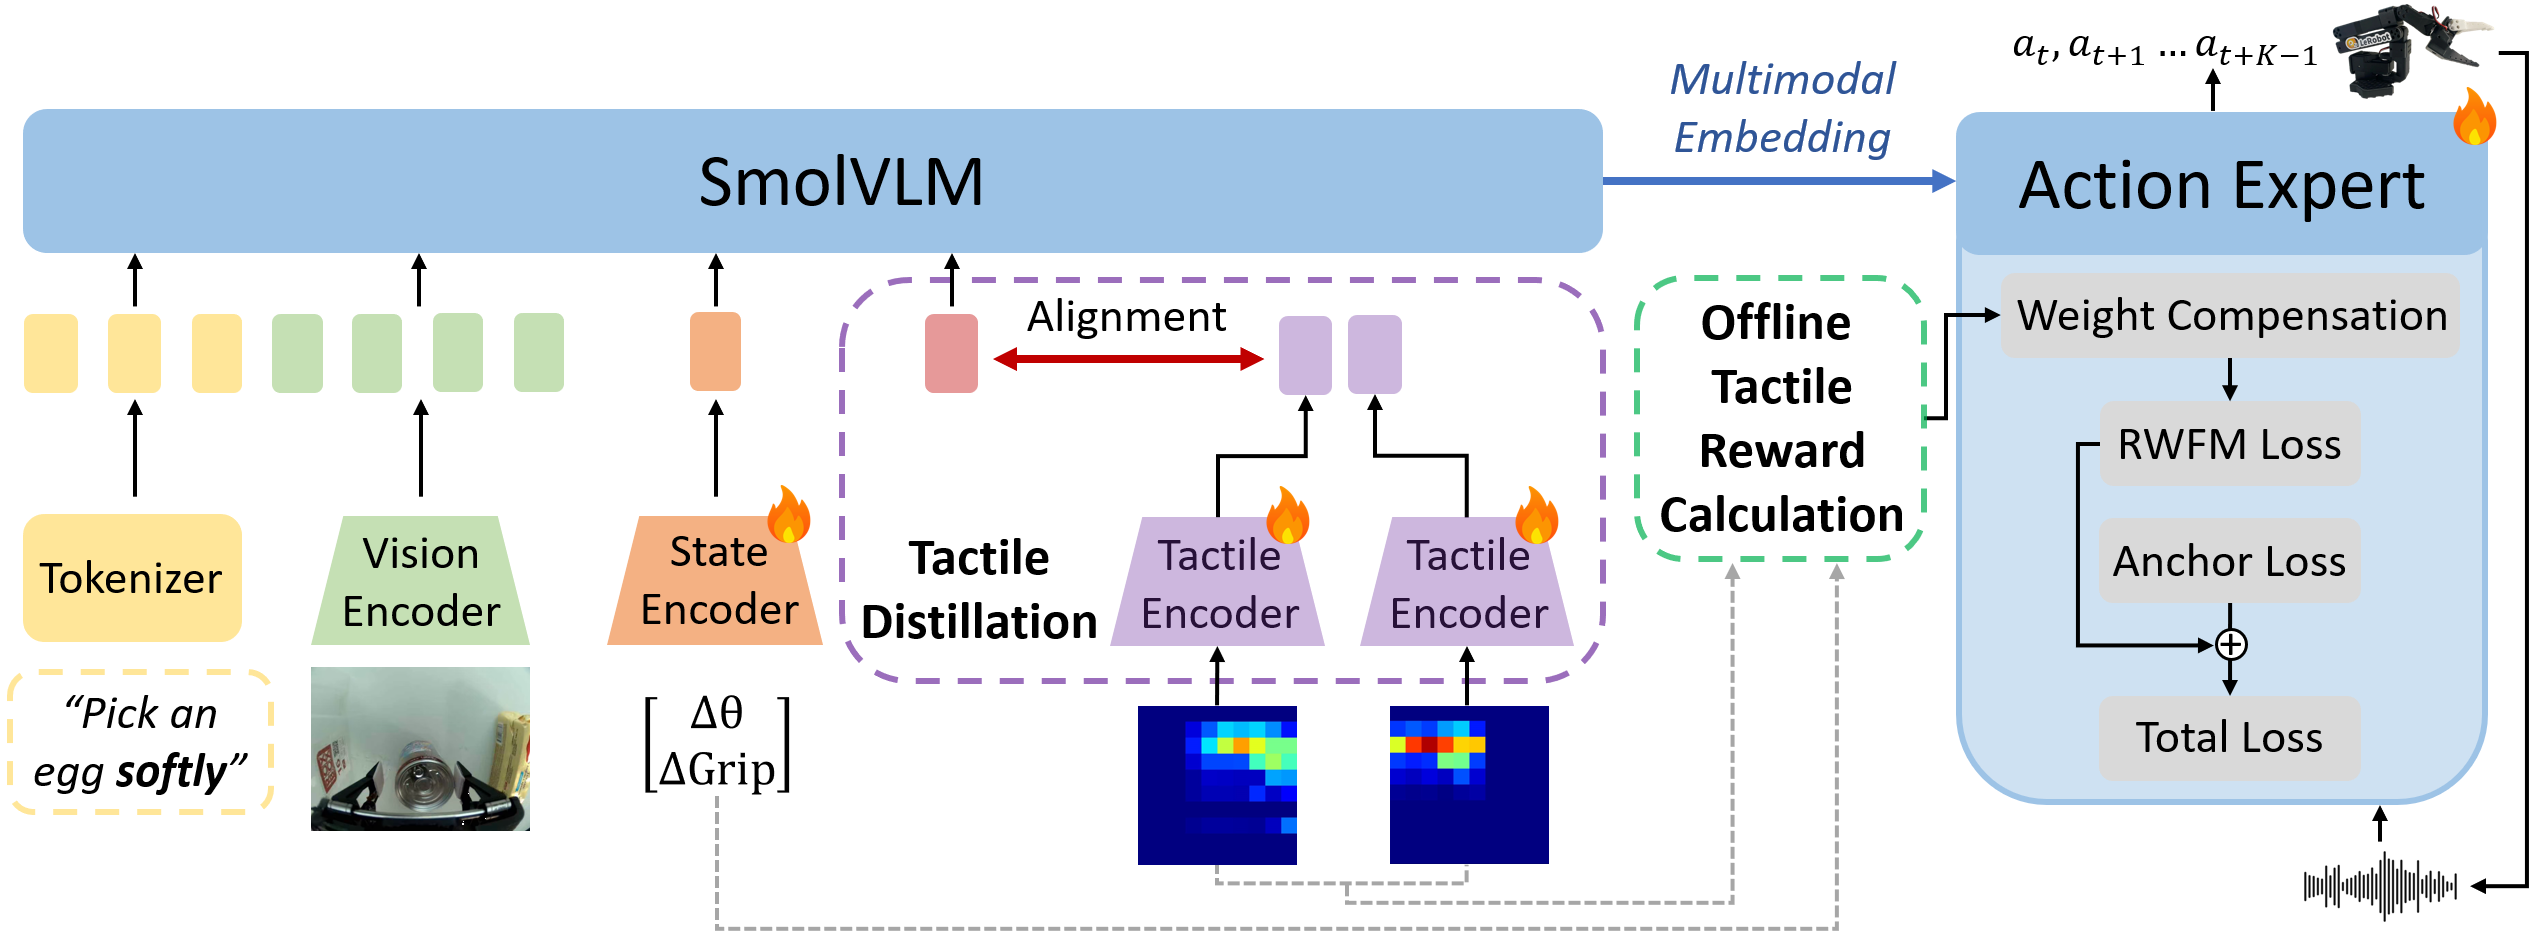
The Intelligent Space Robotics Laboratory (Skoltech) published HapticVLA, accepted to IROS 2026: a VLA model learns gentle contact manipulation, and tactile sensors are only needed during training; at inference, it uses vision and state.
🌍 Tactile sensors for robots are expensive and poorly transferable between platforms. Here, the sense of touch is distilled into the model's weights: during training, the tactile signal serves as a reward and teacher, and is not needed at inference.
👤 On fragile objects, the average success rate is 86.7% — higher than baseline VLAs, even without sensors at inference. The code (a LeRobot fork with a Crab stand of two SO-101s), weights, and datasets are open: it can be reproduced without buying sensors. The work was done by master's students from Yandex and Skoltech's AI Robotics program in six months.
Source 1: https://arxiv.org/abs/2603.15257 Source 2: https://advanced-robotic-manipulation.github.io/websites/hapticvla/