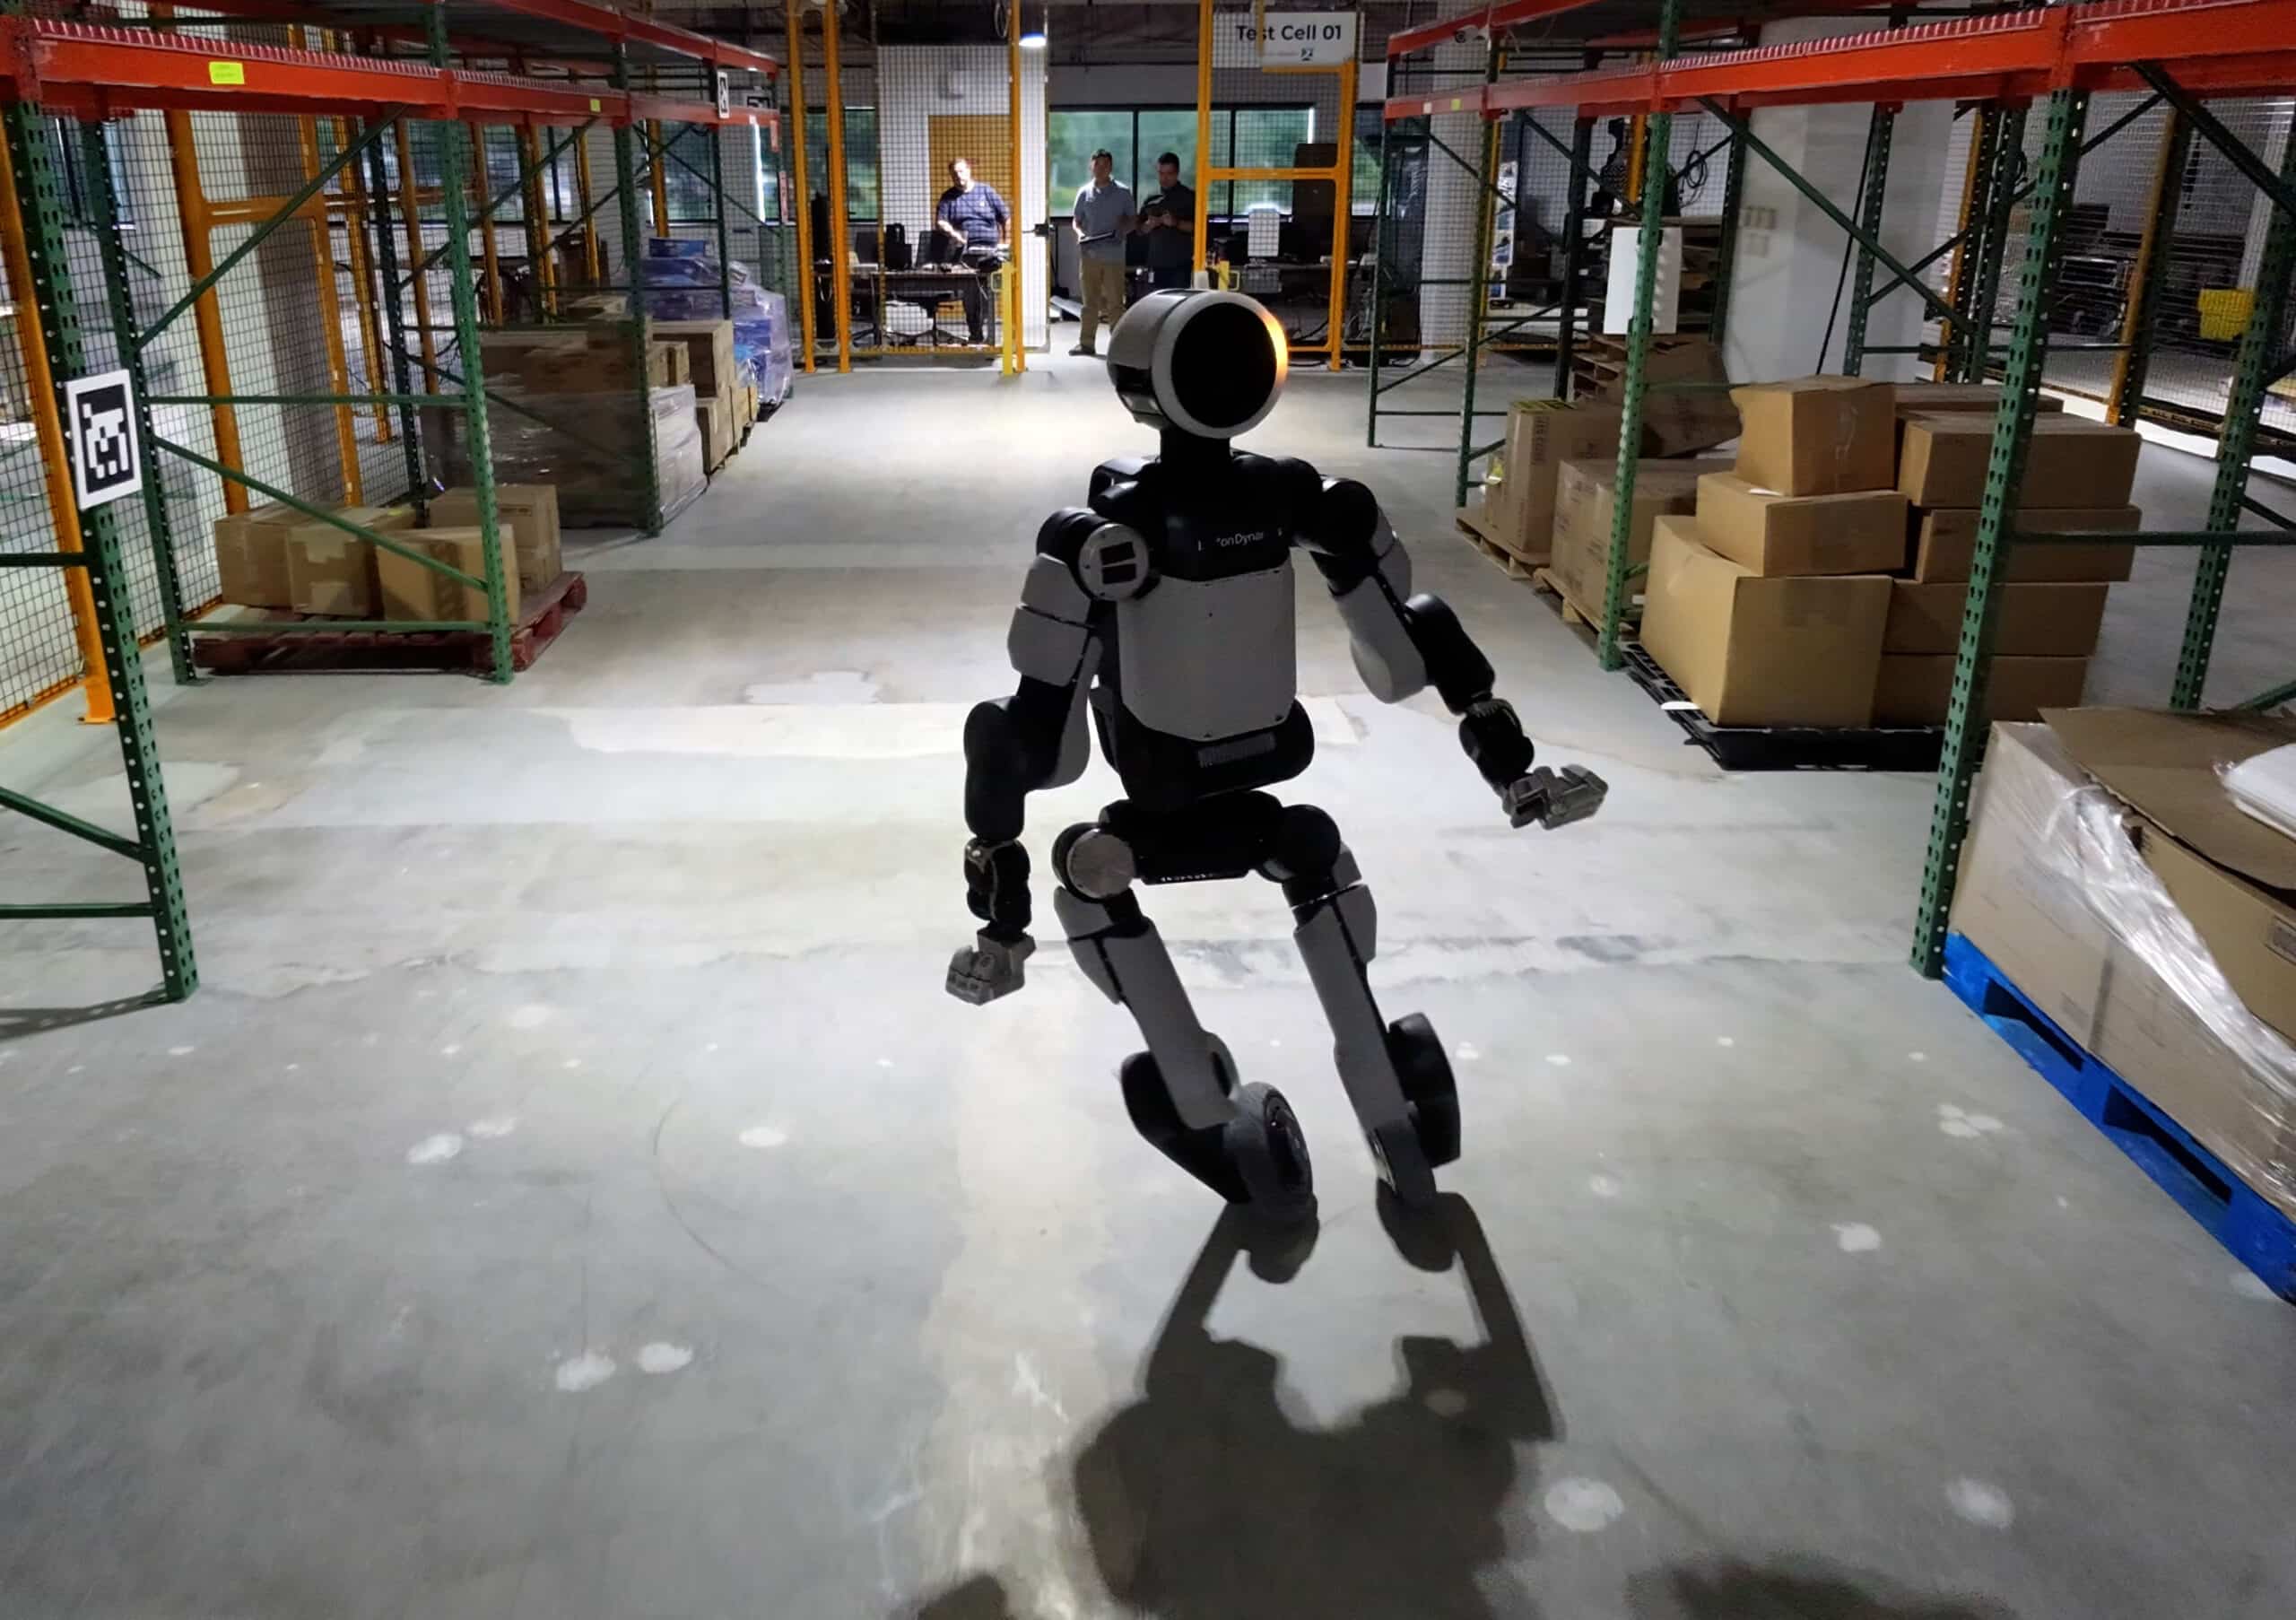
🤖 Boston Dynamics Puts Humanoid Atlas on Wheels
Boston Dynamics attached scooter wheels in place of Atlas's feet: a custom adapter on the standard ankle actuator, with no new parts. The goal was not to create a "wheeled robot," but to test the actuators at their limits — the motors operate continuously across the full range of torque and speed. The whole-body RL policy was trained in simulation over millions of episodes, with the motor model precisely tuned to match real-world measurements.
🌍 Accurate motor models matter more than policy architecture: a policy trained on idealized motors learns movements that the hardware cannot execute. Data on actuator performance at the limits will be used for the standard bipedal Atlas — for fault tolerance.
👤 The robot started using the wheels on its own: it performs lateral lunges with a smooth roll, and executed a 360-degree jump on the first attempt.
Source 1: https://bostondynamics.com/blog/atlas-on-a-roll/ Source 2: https://www.youtube.com/live/NL65Awuv8gU